
As part of its educational and scientific-outreach activities, the Faculty of Medicine held a practical seminar on October 1, 2026, titled "STI Preven
Quotation gallery
Science is organized knowledge. Wisdom is organized life.
Immanuel Kant
Faculty’s news
29 сентября — Всемирный день сердца! В честь этой даты медицинский факультет совместно с психологической службой университета организовал информацион
To foster social and educational engagement, promote medical science, and spark student interest in medical research and knowledge, the "Med-Quiz" bli
29 сентября 2026 года со студентами групп 2 мед 26-1 и 2 мед 26-2 проведён куратором Шилкиной Ольгой Ивановной экологический час на тему «Экология нач
28 сентября 2026 г. состоялся творческий вечер «Мир книг: читаем, обсуждаем, открываем» среди студентов специальности «Фармация». Творческий вечер пр
25 сентября 2026 года со студентами групп ОМ 26-2к, ОМ 26-3 медицинского факультета состоялся круглый стол на тему «Конституция — основа стабильности
16 сентября для студентов медицинского факультета в рамках эдвайзерского часа было проведено мероприятие на тему «Закон и порядок — основа безопасного
The Faculty of History, Economics, and Law hosted a scholarly roundtable titled "Northern Kazakhstan within the Steppe Communication Network of the
The Faculty of History, Economics, and Law hosted a scholarly roundtable titled "Northern Kazakhstan within the Steppe Communication Network of the Go
Проведён семинар по академической политике вуза с участием студентов групп Мед 3-26. В ходе мероприятия обучающиеся ознакомились с основными положения
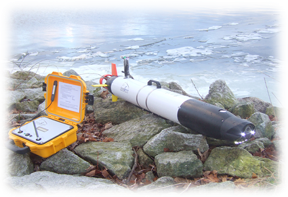
Development of an on-board control system of an autonomous unmanned underwater vehicle, optimal in terms of energy consumption
Priority area: National security and defense
Project manager: Gerasimova Yu.V., Ph.D.
Project executors: Gerasimova Yu.V., Ph.D., Ivel V.P., Ph.D., Avdeev V.N., Ph.D., Moldakhmetov S.S., Master of Technical sciences, doctoral candidate PhD, Petrov P.A., master of technical sciences, doctoral candidate PhD.
Terms of execution: 2019-2021
Amount of financing: 105,000,000 tenge.
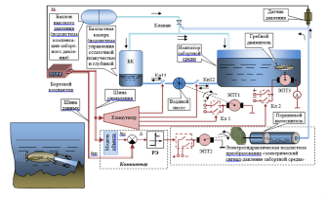
Project goal: Development of a control system for an autonomous unmanned underwater vehicle, as a carrier of special-purpose equipment, ensuring high accuracy when moving and positioning it at a given depth in conditions of external interference from the environment, minimizing energy costs and increasing the duration of autonomous navigation.
Expected results: Development of a computer simulating complex-stand designed to study the operating modes of the AUV control system, its debugging and diagnostics in real time, will reduce the time and cost of developing modern underwater robotic systems intended for military purposes. Obtaining a patent for a utility model.
Description of the project: In recent years, a significant number of autonomous unmanned underwater vehicles (AUVs) have been created in various countries holding a leading position in the field of marine technology to solve a wide range of scientific and applied problems in marine areas.
There is a need for the development and implementation of technologies for the development and creation of underwater robotics in the Republic of Kazakhstan.
Project objectives:
−application of the parametric identifier of nonlinear hydrodynamic parameters of the AUV in order to optimize control processes;
−development of a dual-processor on-board control system based on 32-bit ARM processors for the implementation of algorithms for parallel signal processing;
−development of a hardware and software bench that allows for semi-natural tests of the control system, including sensors and a complex of electromechanical, hydraulic and pneumatic actuators.